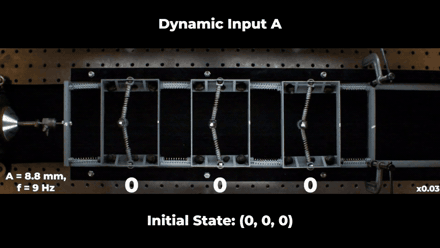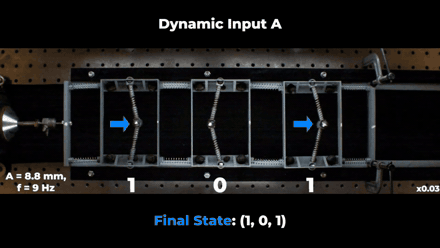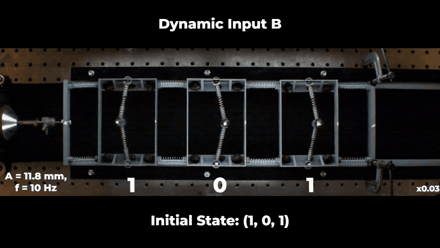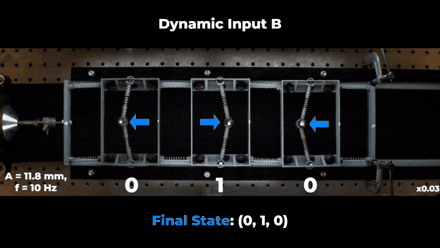
Mechanical metamaterials composed of bistable elements have recently emerged as promising platforms for mechanical memory. Traditional approaches to writing information in these systems typically rely on localized actuation or predefined coupling schemes, which are often labor-intensive or lack adaptability. In this Letter, we introduce a one-dimensional metamaterial consisting of mass-in-mass bistable units that are statically decoupled yet dynamically switchable, allowing arbitrary mechanical information to be encoded through nonlinear waves applied at the boundary of the system. Through a combination of experiments and simulations, we demonstrate that tailored input signals can selectively trigger state transitions deep within the structure, enabling remote and programmable bit writing. This approach opens a new avenue for mechanical memory, harnessing the robustness of bistable elements and the tunability of nonlinear wave-driven actuation.
@article{watkins2026arbitrary,title={Arbitrary mechanical memory encoding via nonlinear waves in bistable metamaterials},author={Watkins, A. A. and Bordiga, G. and Mu, M. and Tournat, V. and Bertoldi, K.},year={2026},month=aug,journal={Physical Review Letters},volume={137},number={9},pages={097201},issn={0031-9007, 1079-7114},doi={10.1103/pkk5-dykb},archiveprefix={arXiv},}
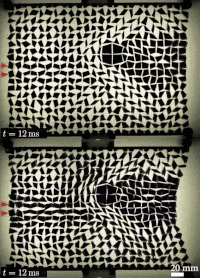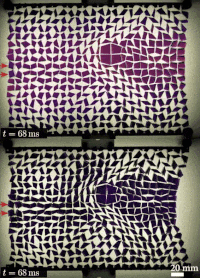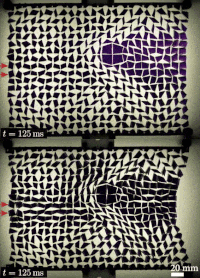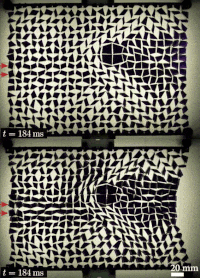
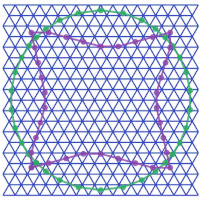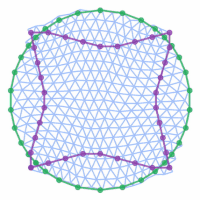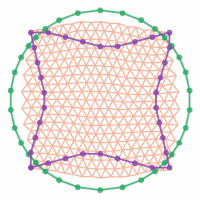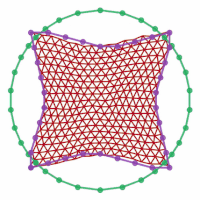
The concept of cloaking—hiding objects from external detection—has seen wide success in linear systems. Yet, translating these advancements to nonlinear mechanical systems remains an open challenge. Here, we present a new approach to nonlinear mechanical cloaking that frames cloaking as an optimization problem aimed at replicating a target mechanical response. This problem is solved using a differentiable simulation framework coupled with gradient-based optimization. This approach is implemented in a class of mechanical metamaterials constructed from rigid units with elastic couplings that support large deformation and contact interactions. Using both numerical simulations and physical experiments, optimal cloak structures are designed that effectively mask internal inhomogeneities and shield against external mechanical disturbances both in static and dynamic regimes. This approach provides a versatile design paradigm for creating mechanical systems with integrated cloaking functionality across a broad range of loading scenarios.
@article{bordiga2025nonlinear,title={Nonlinear mechanical metamaterial cloaks},author={Bordiga, G. and Argaud, J.-G. and Watkins, A. A. and Tournat, V. and Bertoldi, K.},year={2025},month=dec,journal={Advanced Functional Materials},pages={e22895},issn={1616-3028},doi={10.1002/adfm.202522895},archiveprefix={arXiv},}
Harnessing the rich nonlinear dynamics of highly deformable materials has the potential to unlock the next generation of functional smart materials and devices. However, unlocking such potential requires effective strategies to spatially engineer material architectures within the nonlinear dynamic regime. Here we introduce an inverse-design framework to discover flexible mechanical metamaterials with a target nonlinear dynamic response. The desired dynamic task is encoded via optimal tuning of the full-scale metamaterial geometry through an inverse-design approach powered by a fully differentiable simulation environment. By deploying such a strategy, mechanical metamaterials are tailored for energy focusing, energy splitting, dynamic protection and nonlinear motion conversion. Furthermore, our design framework can be expanded to automatically discover reprogrammable architectures capable of switching between different dynamic tasks. For instance, we encode two strongly competing tasks—energy focusing and dynamic protection—within a single architecture, using static precompression to switch between these behaviours. The discovered designs are physically realized and experimentally tested, demonstrating the robustness of the engineered tasks. Our approach opens an untapped avenue towards designer materials with tailored robotic-like reprogrammable functionalities.
@article{bordiga2024automated,title={Automated discovery of reprogrammable nonlinear dynamic metamaterials},author={Bordiga, G. and Medina, E. and Jafarzadeh, S. and B{\"o}sch, C. and Adams, R. P. and Tournat, V. and Bertoldi, K.},year={2024},month=sep,journal={Nature Materials},volume={23},number={11},pages={1486--1494},issn={1476-4660},doi={10.1038/s41563-024-02008-6},archiveprefix={arXiv},}
An integrated design, modeling, and multi-material 3D printing platform for fabricating liquid crystal elastomer (LCE) lattices in both homogeneous and heterogeneous layouts with spatially programmable nematic director order and local composition is reported. Depending on their compositional topology, these lattices exhibit different reversible shape-morphing transformations upon cycling above and below their respective nematic-to-isotropic transition temperatures. Further, it is shown that there is good agreement between their experimentally observed deformation response and model predictions for all LCE lattice designs evaluated. Lastly, an inverse design model is established and the ability to print LCE lattices with the predicted deformation behavior is demonstrated. This work opens new avenues for creating architected LCE lattices that may find potential application in energy-dissipating structures, microfluidic pumping, mechanical logic, and soft robotics.
@article{kotikian2024liquid,title={Liquid crystal elastomer lattices with thermally programmable deformation via multi-material 3D printing},author={Kotikian, A. and Watkins, A. A. and Bordiga, G. and Spielberg, A. and Davidson, Z. S. and Bertoldi, K. and Lewis, J. A.},year={2024},month=jan,journal={Advanced Materials},volume={36},number={34},pages={2310743},issn={1521-4095},doi={10.1002/adma.202310743},}

 Hey there!